3D printing for architecture
3D ModelingYour Imagination
Uro Fab Support is a 3D printing workshop run by engineers in Dhaka. We print detailed scale models for architects, developers and design competitions, straight from your files.
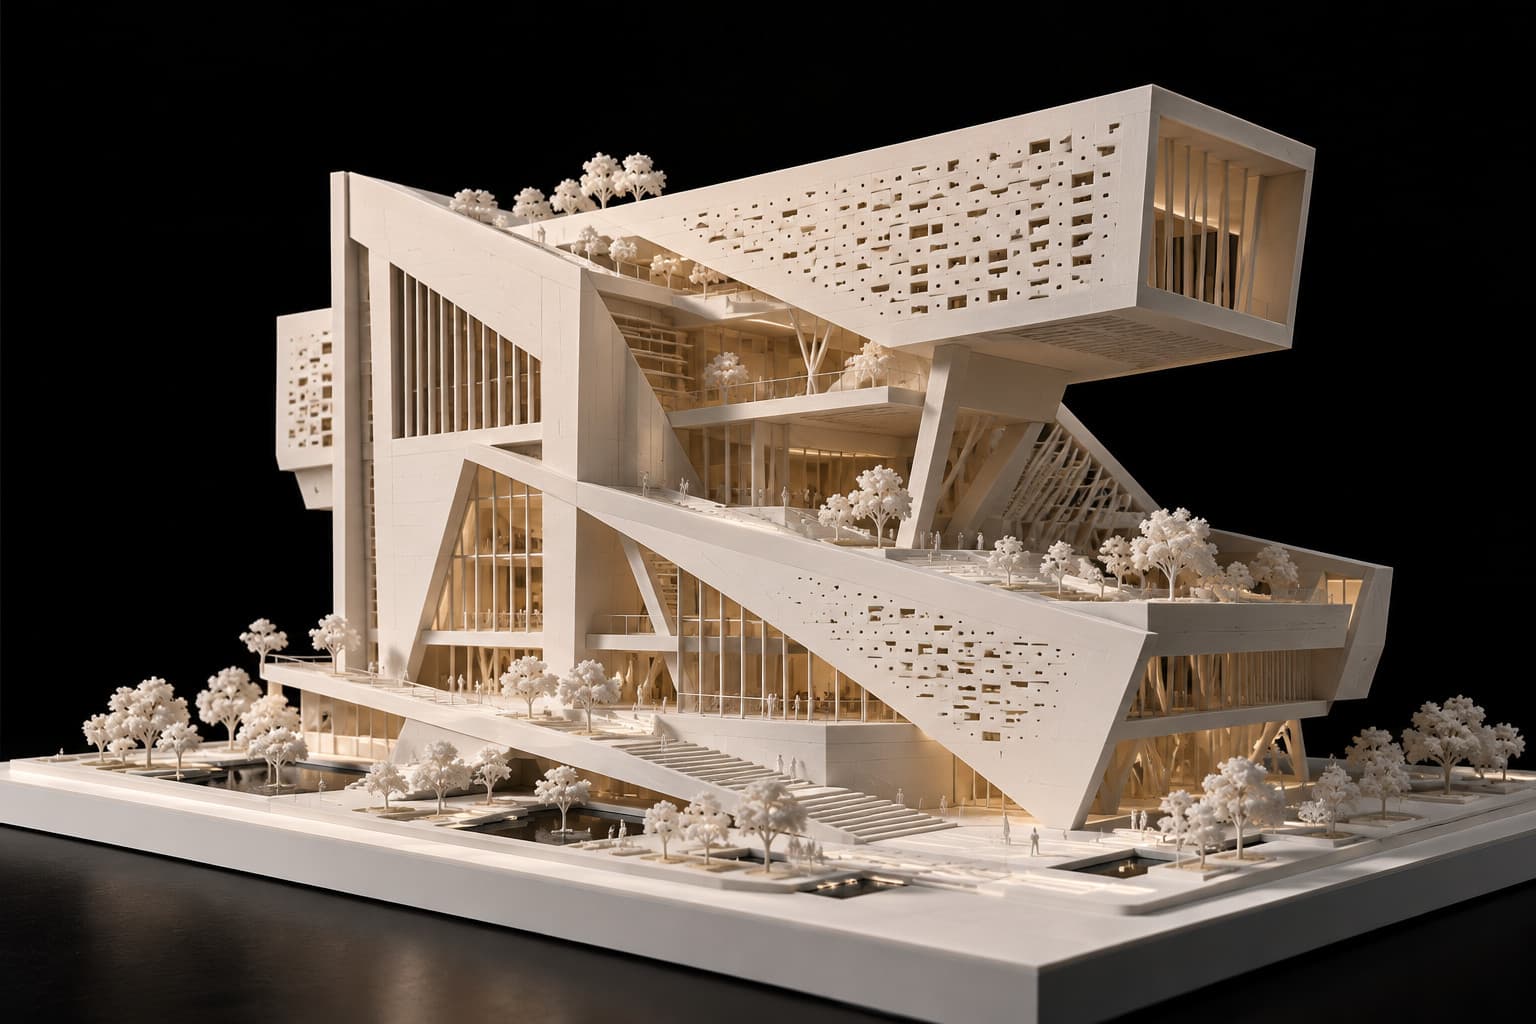
3D printed in-house
On our own printers, in our workshop in Dhaka.
Prepared by engineers
The people who design Uro's robots set up every print.
Print from your files
STL, OBJ, 3MF, STEP, Revit, SketchUp or Rhino.
- 3D printed scale models
- Competition models
- Sales gallery models
- Master plans
- Massing studies
- Exhibition pieces
How we 3D print
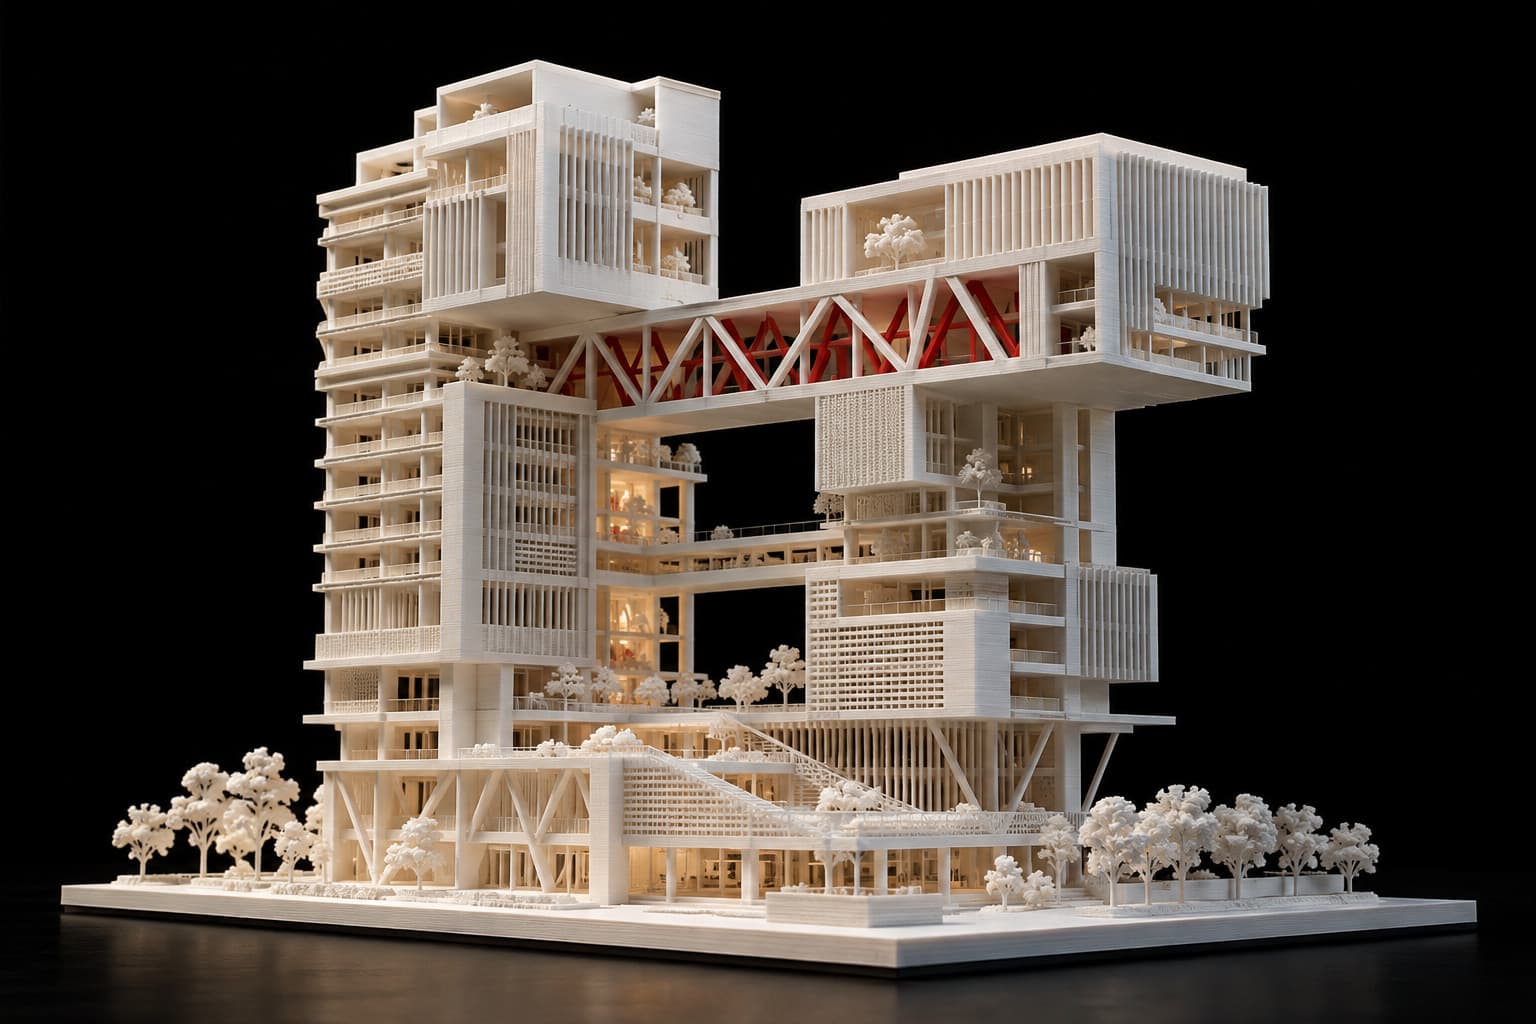
Printed layer by layer
Every model is 3D printed in fine layers on our own printers, so the detail in your drawings makes it into the model.
What we print
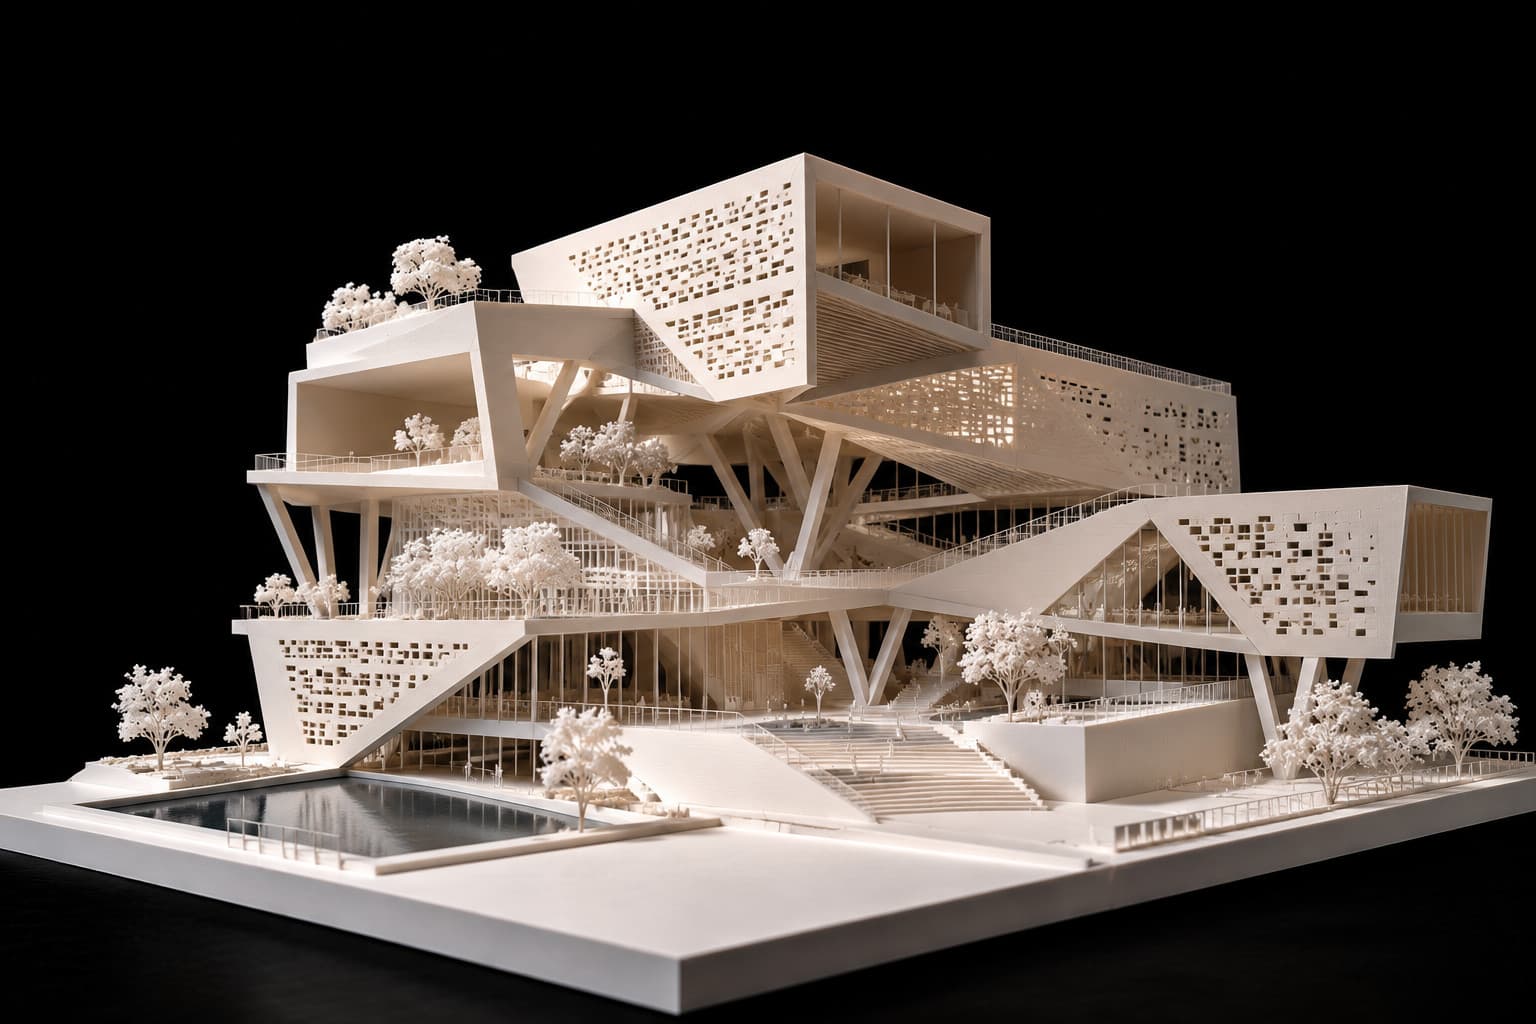
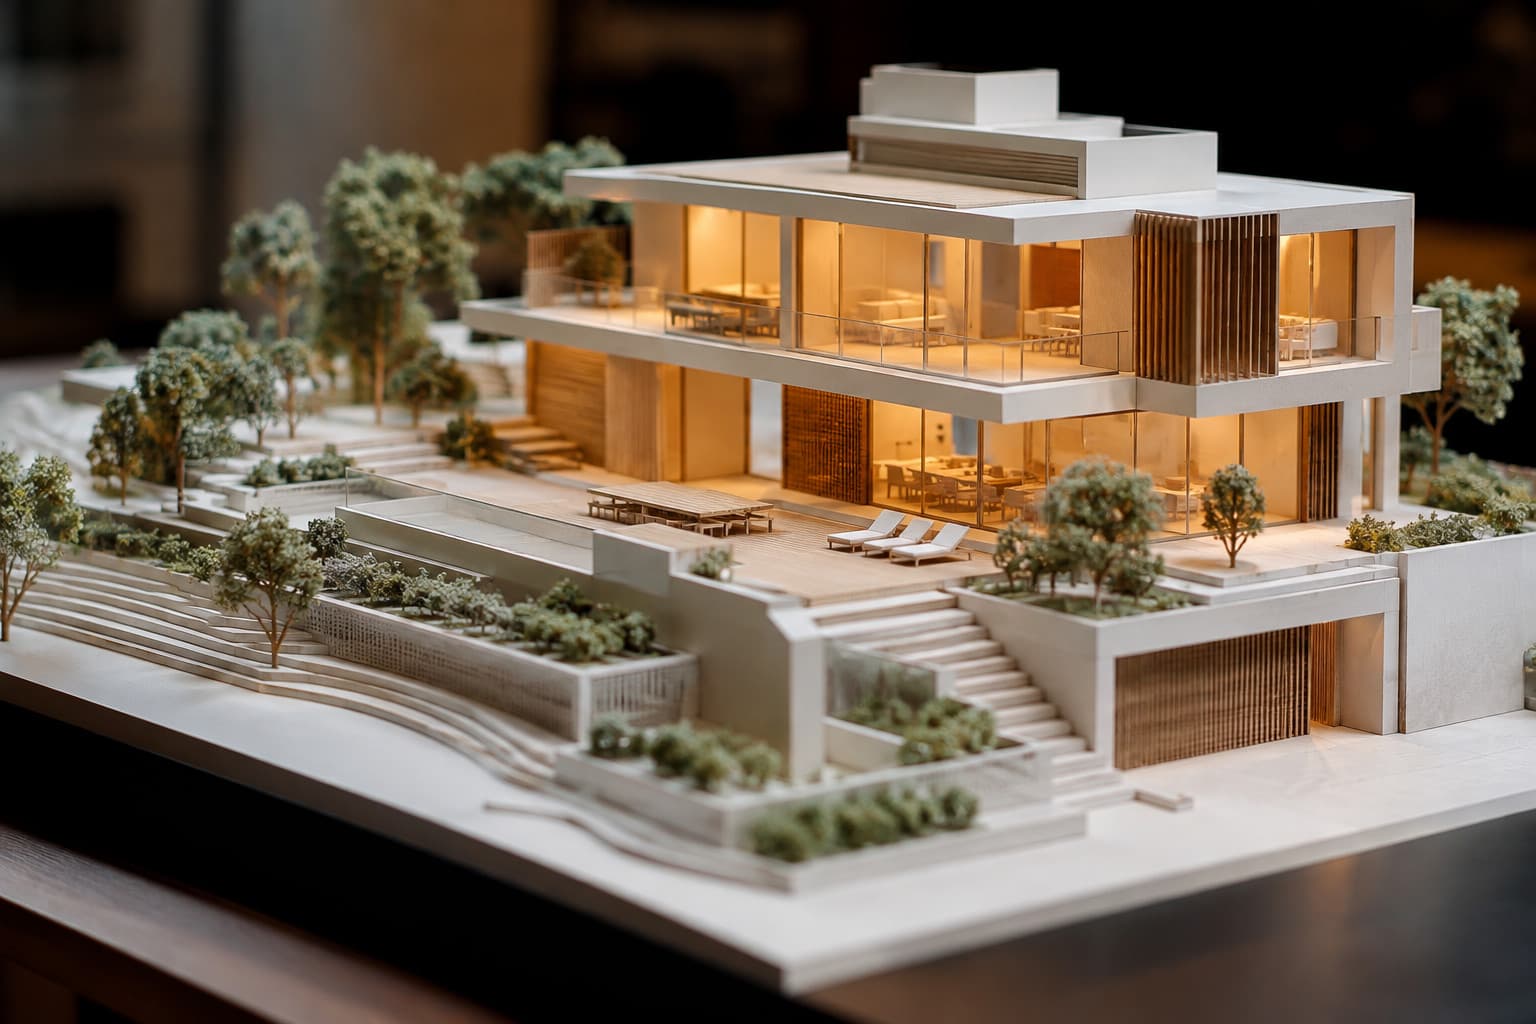
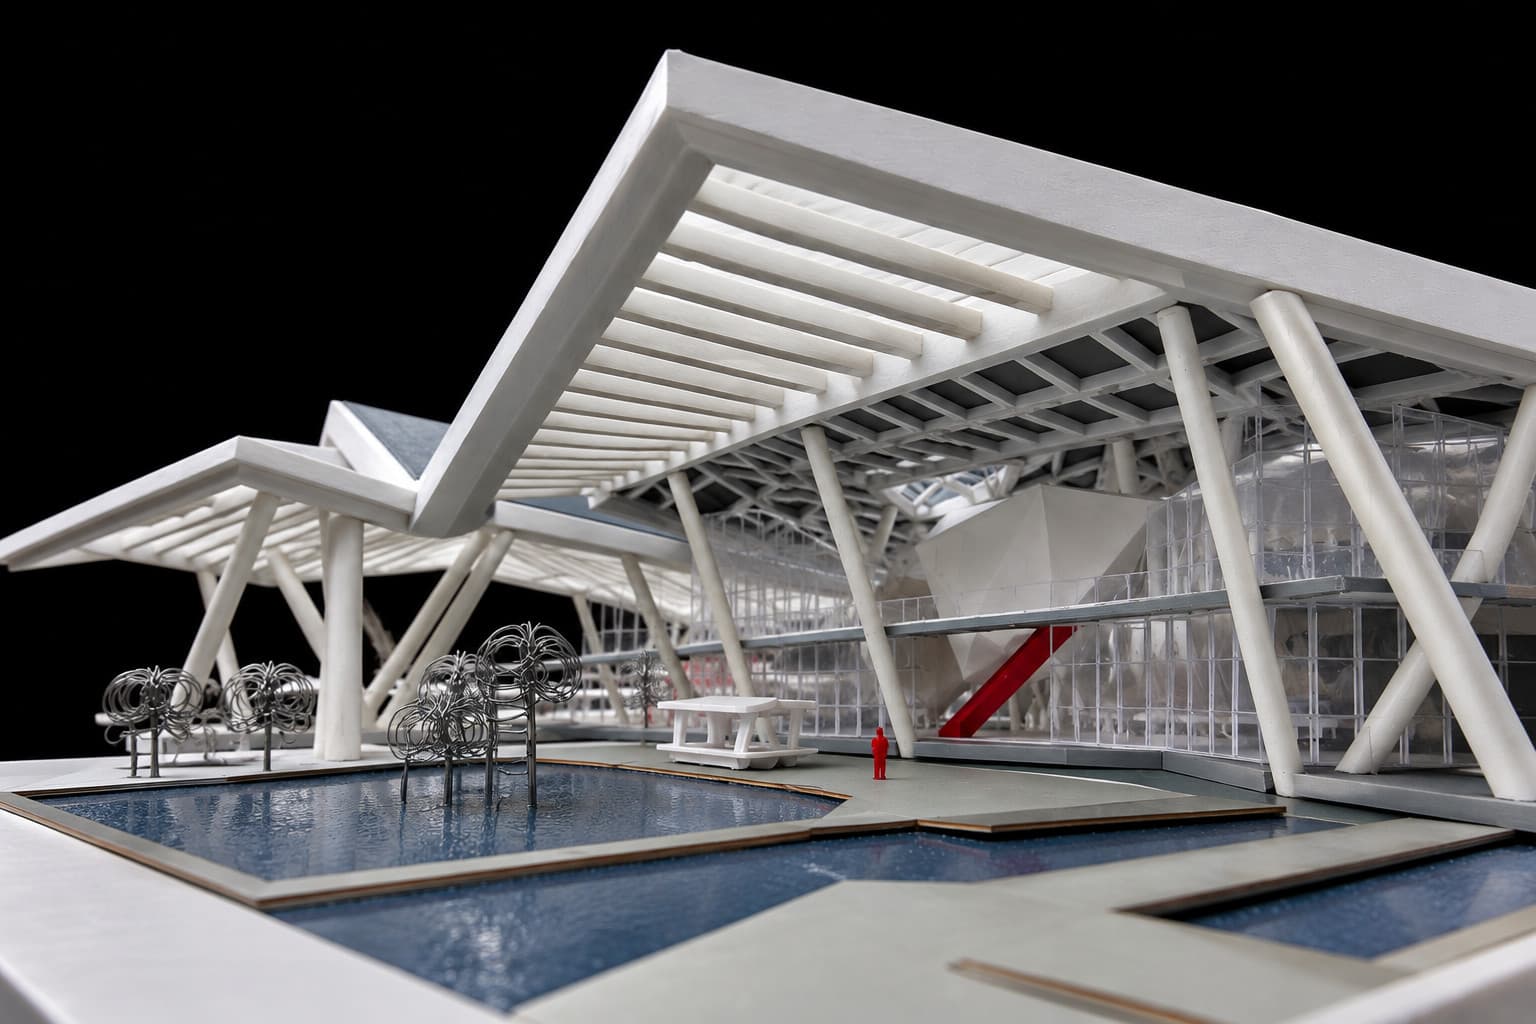
Scale models, from a private home to a city landmark.
Why Uro Fab Support
Made by engineers, finished like a presentation piece.
Engineered, not just printed
Engineers set up every print, so parts fit, joints hold and the model survives the trip to your client.
Fine layers
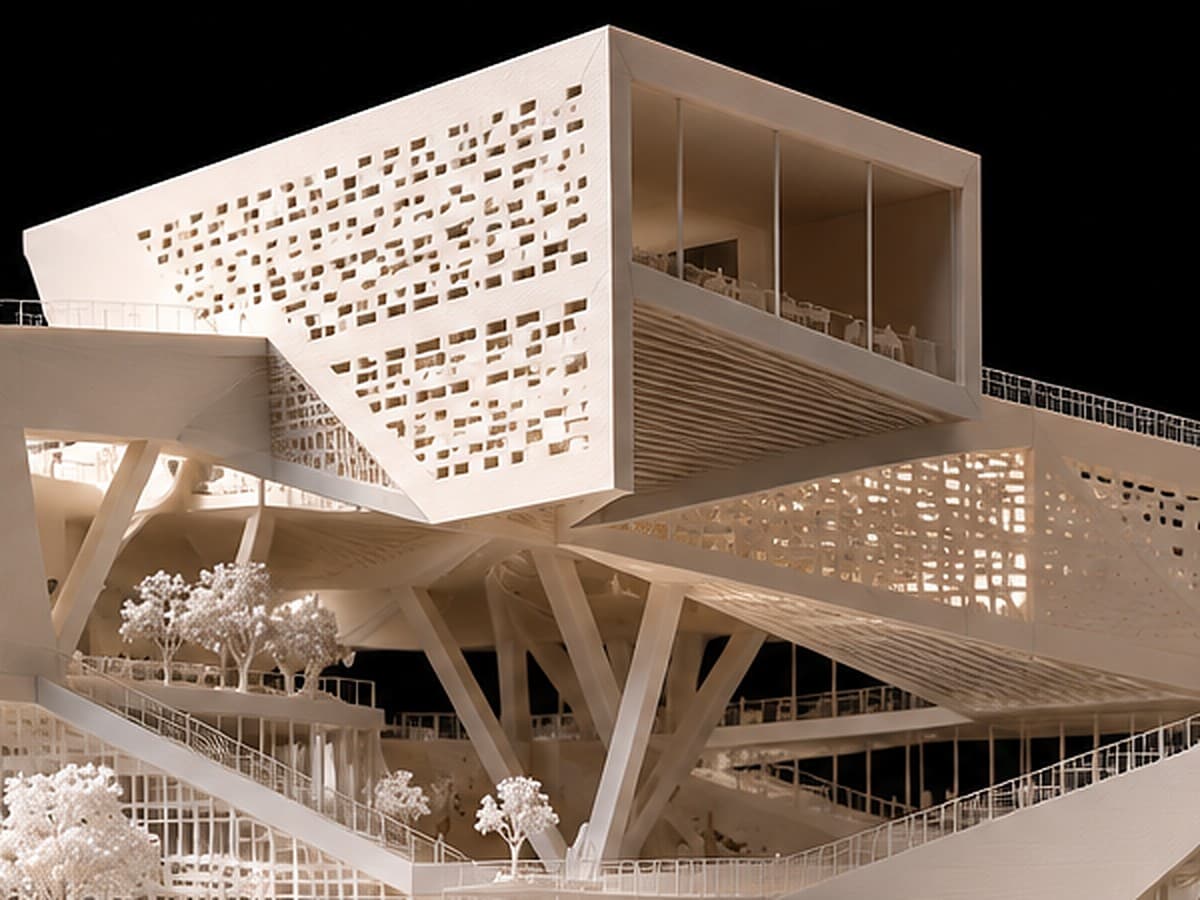
Floor plates, railings, facade fins and trees come out crisp at the scale you need.
Big sites, in parts
Large models are printed in sections and assembled on a finished base.
No 3D file? No problem
Our engineers model it from your plans and sections, then print it.
Facades
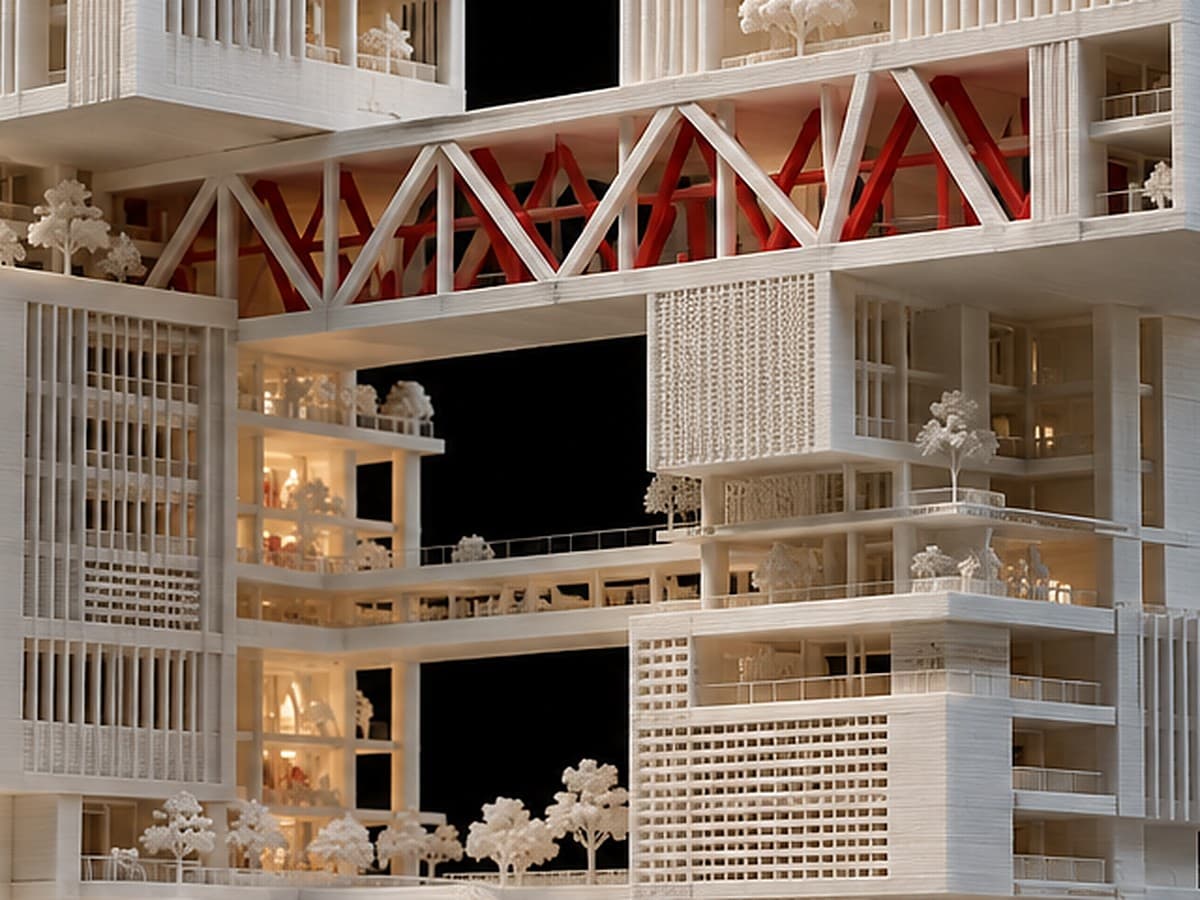
Structure
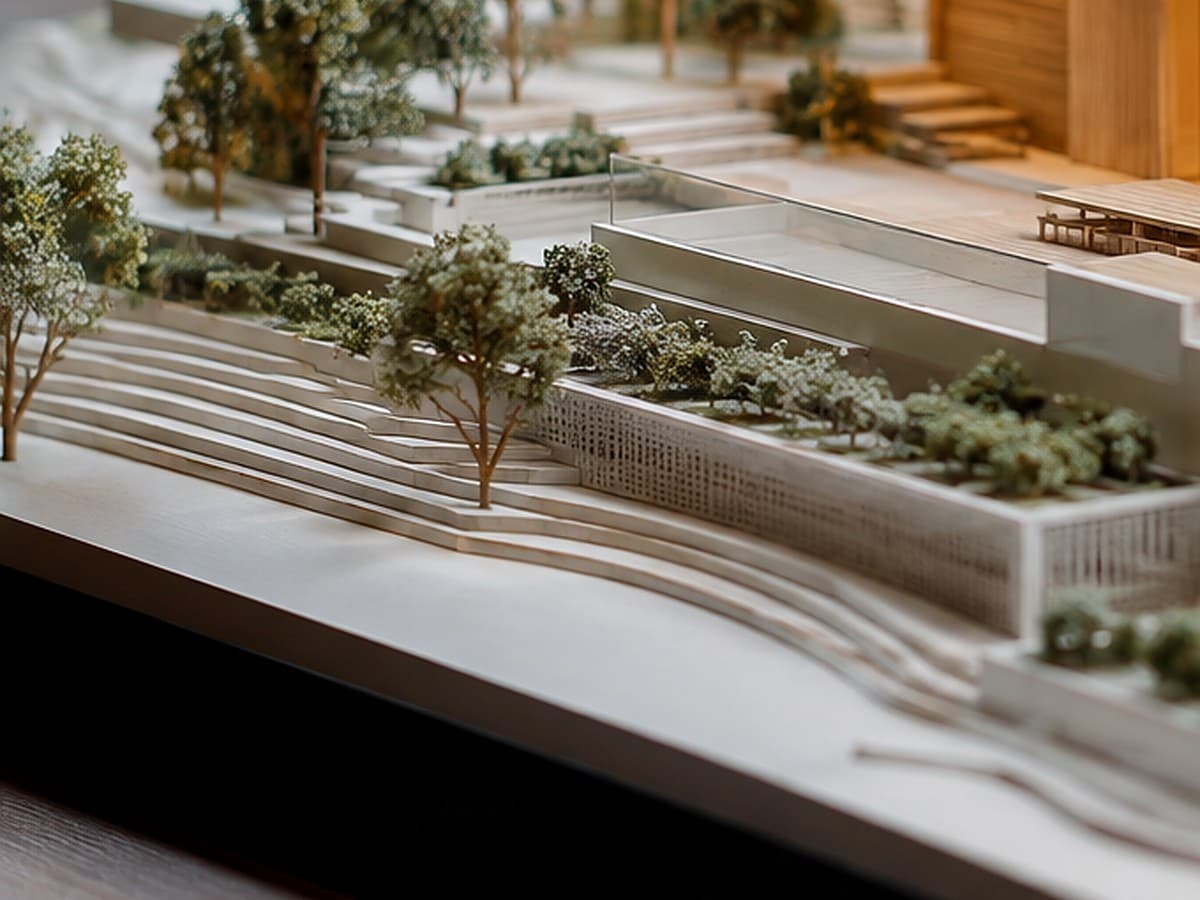
Landscape
How it works
From your file to a finished model.
01
Send your files
A 3D model or your drawings, with the scale and size you need. We send back a price and a date.
02
We prepare the print
Our engineers check the model, set the scale and split big sites into parts that print cleanly.
03
We 3D print it
Layer by layer, on our own printers, in our workshop in Dhaka.
04
Finished and delivered
Cleaned up, finished in white and assembled on its base, ready to present.
We print from
- STL
- OBJ
- 3MF
- STEP
- Revit
- SketchUp
- Rhino
- PDF drawings
Also from the workshop
Robotics parts, circuit boards and the code that runs them.
- CAD · Robot part and architectural modelSketchExtrudeFilletHoleAssemblyChecked by an engineer
Model
- Servo bracket
- Base plate
- Side walls
- Bolt holes ×6
- Pavilion
- Podium
- Floor plates ×9
- Wing
Robot partSafety factor 2.4 · 128 gArchitectural modelScale 1 : 2003D design
Robotics parts and architectural models, designed in CAD by our engineers.
- PCB layout · Sensor boardTop view · 2 layers
Layers
Top copperBottom copperSilkscreenBoard outlineGround pourDesign rules
0 errors
Board50 × 32 mmNets42Export for manufacture - Firmware · motor_control.c
firmware
- src/
- main.c
- motor_control.c
- sensors.c
- radio.c
- include/
- config.h
1// Keep the motor at the speed it is asked for2void motor_update(motor_t *m, float target) {3 float error = target - encoder_rpm(m->enc);4 m->integral += error * DT;5 float out = KP * error + KI * m->integral6 + KD * (error - m->last) / DT;7 m->last = error;8 pwm_write(m->pwm, clamp(out, -1.0f, 1.0f));9}1011void loop(void) {12 for (int i = 0; i < MOTORS; i++)13 motor_update(&motors[i], targets[i]);14}Serial monitorBuild passed · 14.2 kB[12.402] imu ok · temp 31.2 C
[12.410] motor 1 · 4120 rpm · pwm 0.62
[12.418] motor 2 · 4096 rpm · pwm 0.61
Firmware development
Embedded code for sensors, motors and controllers, tested on the hardware.
Start a model
Have a model to print?
Send us your files or drawings and we will come back with a plan, a price and a date.