Prohori
An autonomous quadcopter that finds marked targets from the air and drops a payload on each one.
Best International Team · TEKNOFEST 2026, Turkiye
- Category
- Autonomous payload UAV
- Domain
- Aerial
- Year
- 2026
- Status
- Competition aircraft
Overview
Built for the TEKNOFEST 2026 International UAV Competition, rotary wing.
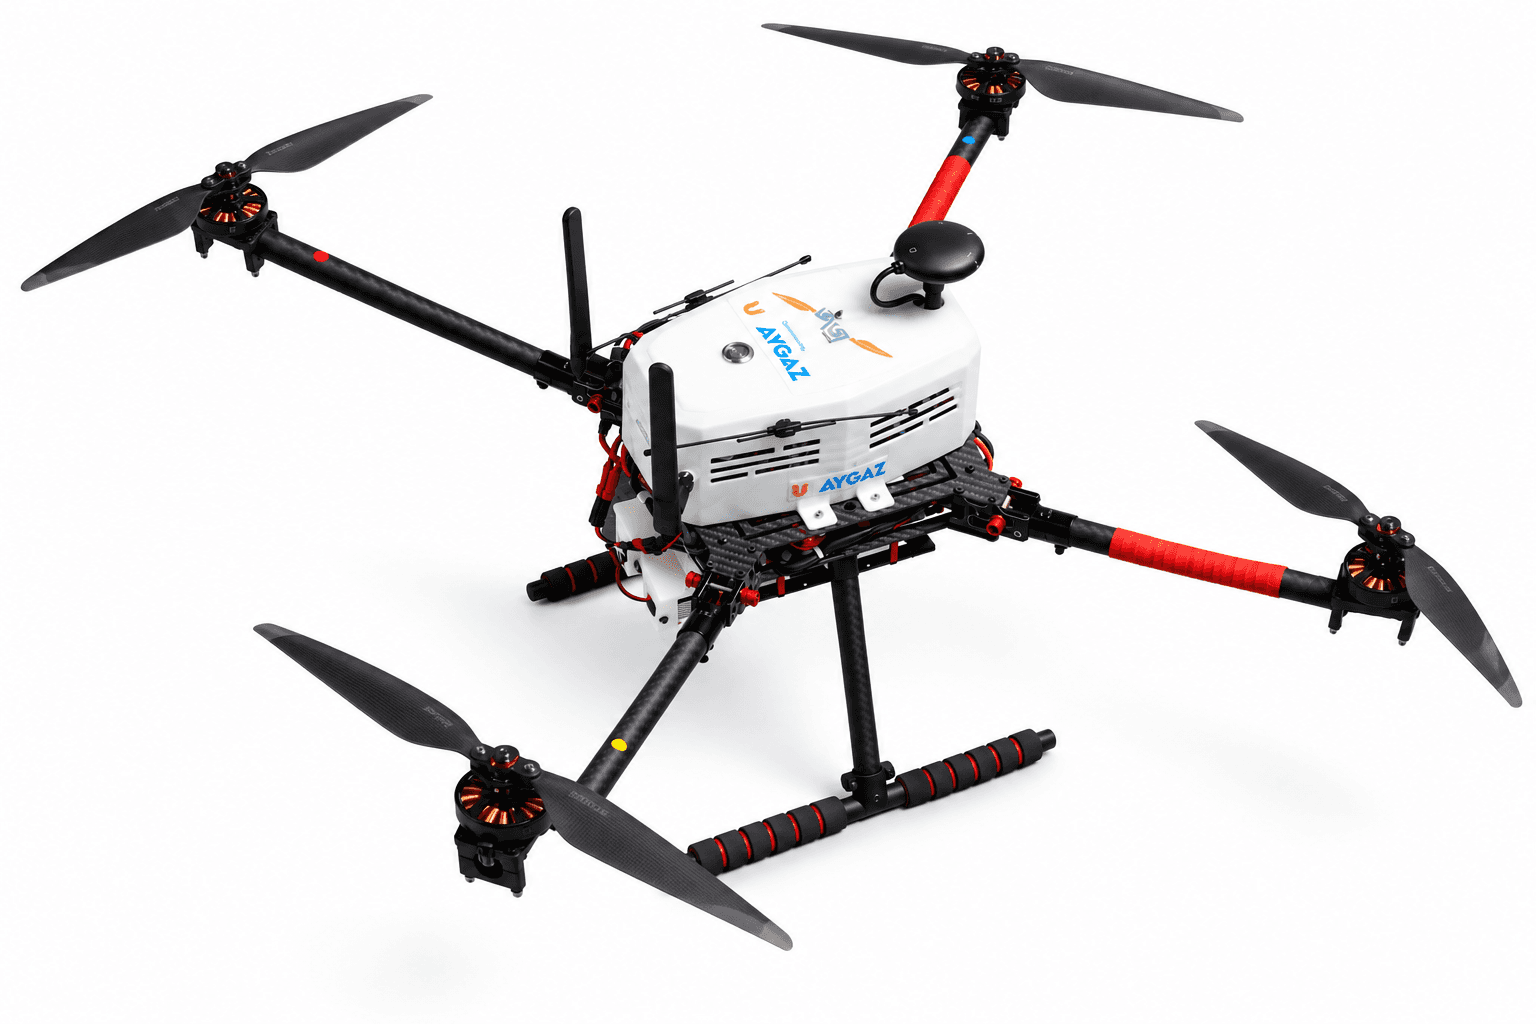
Prohori searches a field on its own, recognises two marked targets with an on-board AI camera and releases a 600 g payload onto each. At the TEKNOFEST 2026 International UAV Competition in Türkiye it was named Best International Team, finished second in Asia and placed in the top 10 in the world.
Prohori was built for the rotary-wing category of the TEKNOFEST 2026 International UAV Competition in Türkiye. The mission: search a marked field, find a red triangle and a blue hexagon, and deliver a payload onto each one with no pilot steering.
A Raspberry Pi 5 with a Raspberry Pi AI Camera looks straight down and runs detection on board. It sends each target's position to a Pixhawk 6X running ArduPilot over MAVLink, and the Pixhawk flies the approach and fires the release.
The airframe is a 682 mm carbon fibre X-frame on T-Motor MN4006 motors and 15 inch carbon propellers, with two payload bays carrying 1.2 kg between them. Every part of the mission was rehearsed in a Gazebo simulation before it flew.
Results
All achievements01
2nd
In Asia
02
Top 10
In the world
03
Winner
Best International Team award
Specifications
- Frame
- 682 mm carbon X-frame
- Propulsion
- T-Motor MN4006, 15 in props
- Flight control
- Pixhawk 6X, ArduPilot
- Companion computer
- Raspberry Pi 5
- Vision
- Pi AI Camera, facing down
- Payload
- 2 bays, 600 g each
- Data link
- SIYI HM30
- Navigation
- u-blox M10 GNSS
- Design score
- 84.33 / 100, preliminary
Technology
- ArduPilot
- Pixhawk 6X
- Raspberry Pi 5
- On-board vision
- MAVLink
- Gazebo SITL