Octobot
An eight-thruster underwater robot built around a sealed tube hull, built during UIU Mariner 2025
- Category
- Underwater ROV
- Domain
- Marine
- Year
- 2025
- Status
- Two generations
Overview
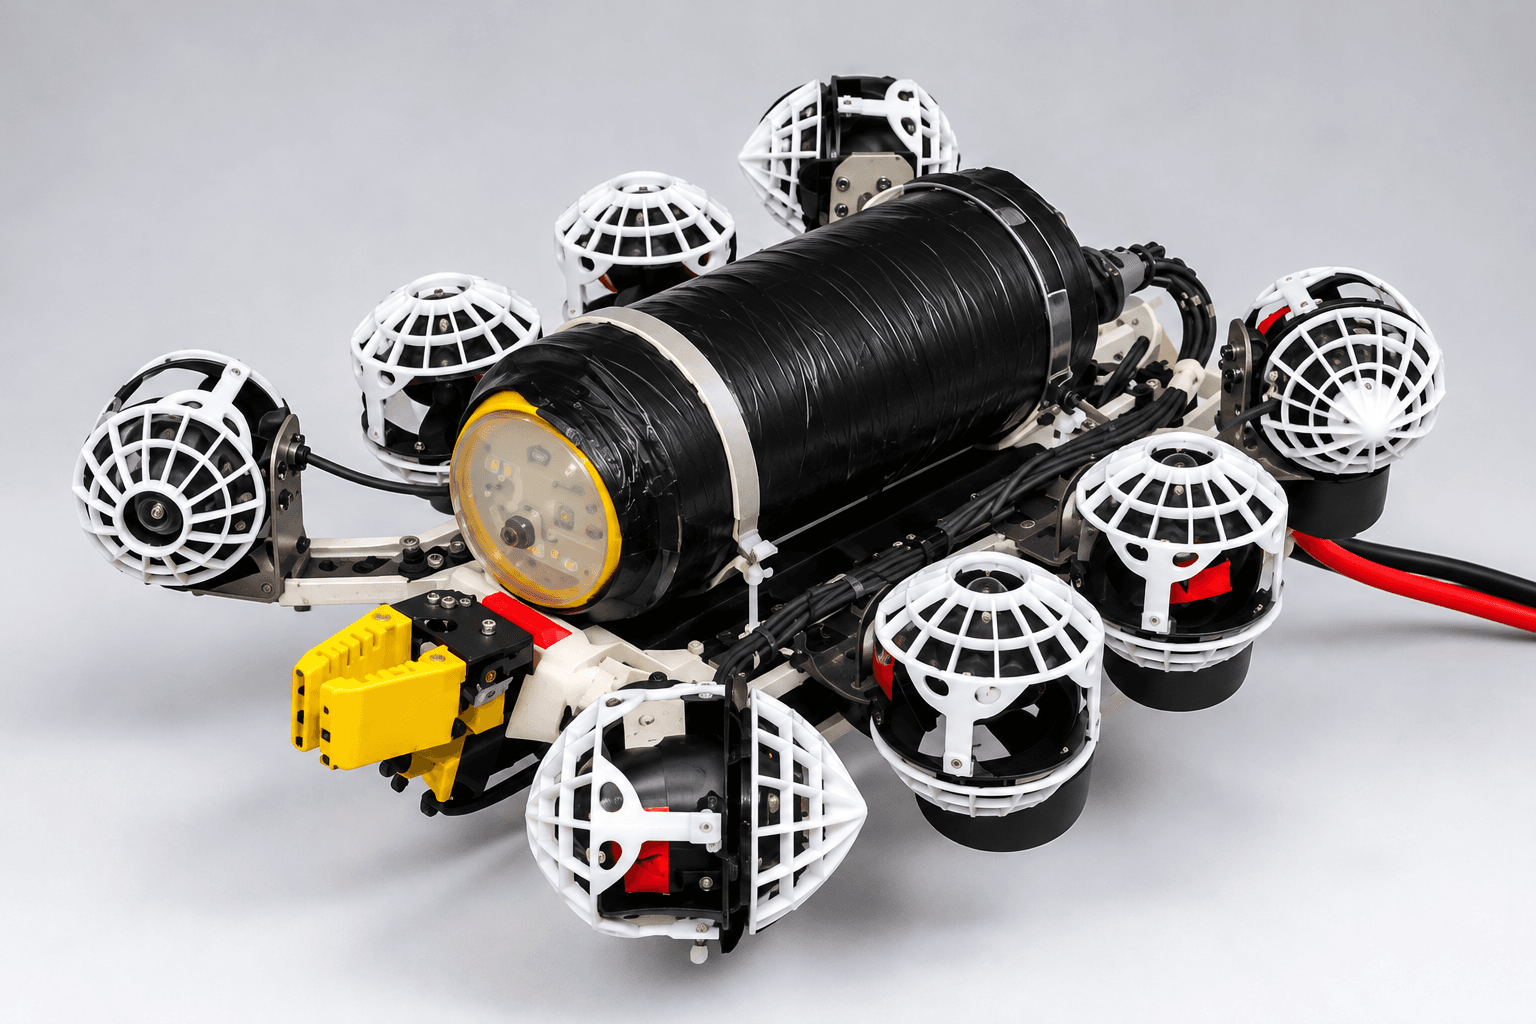
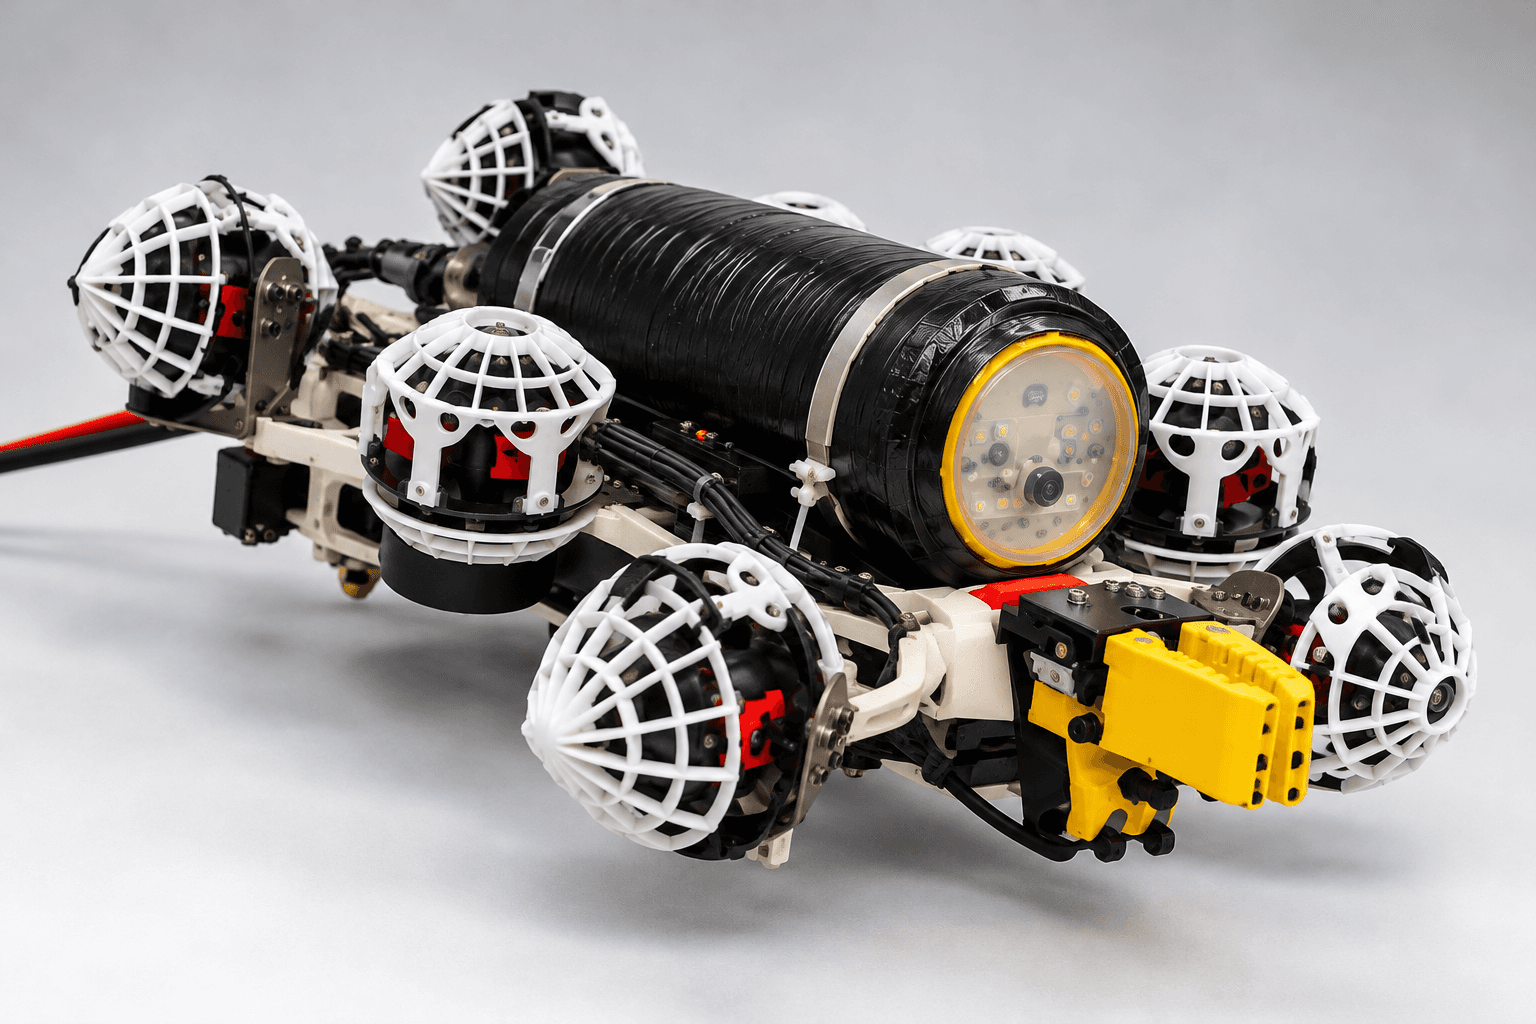
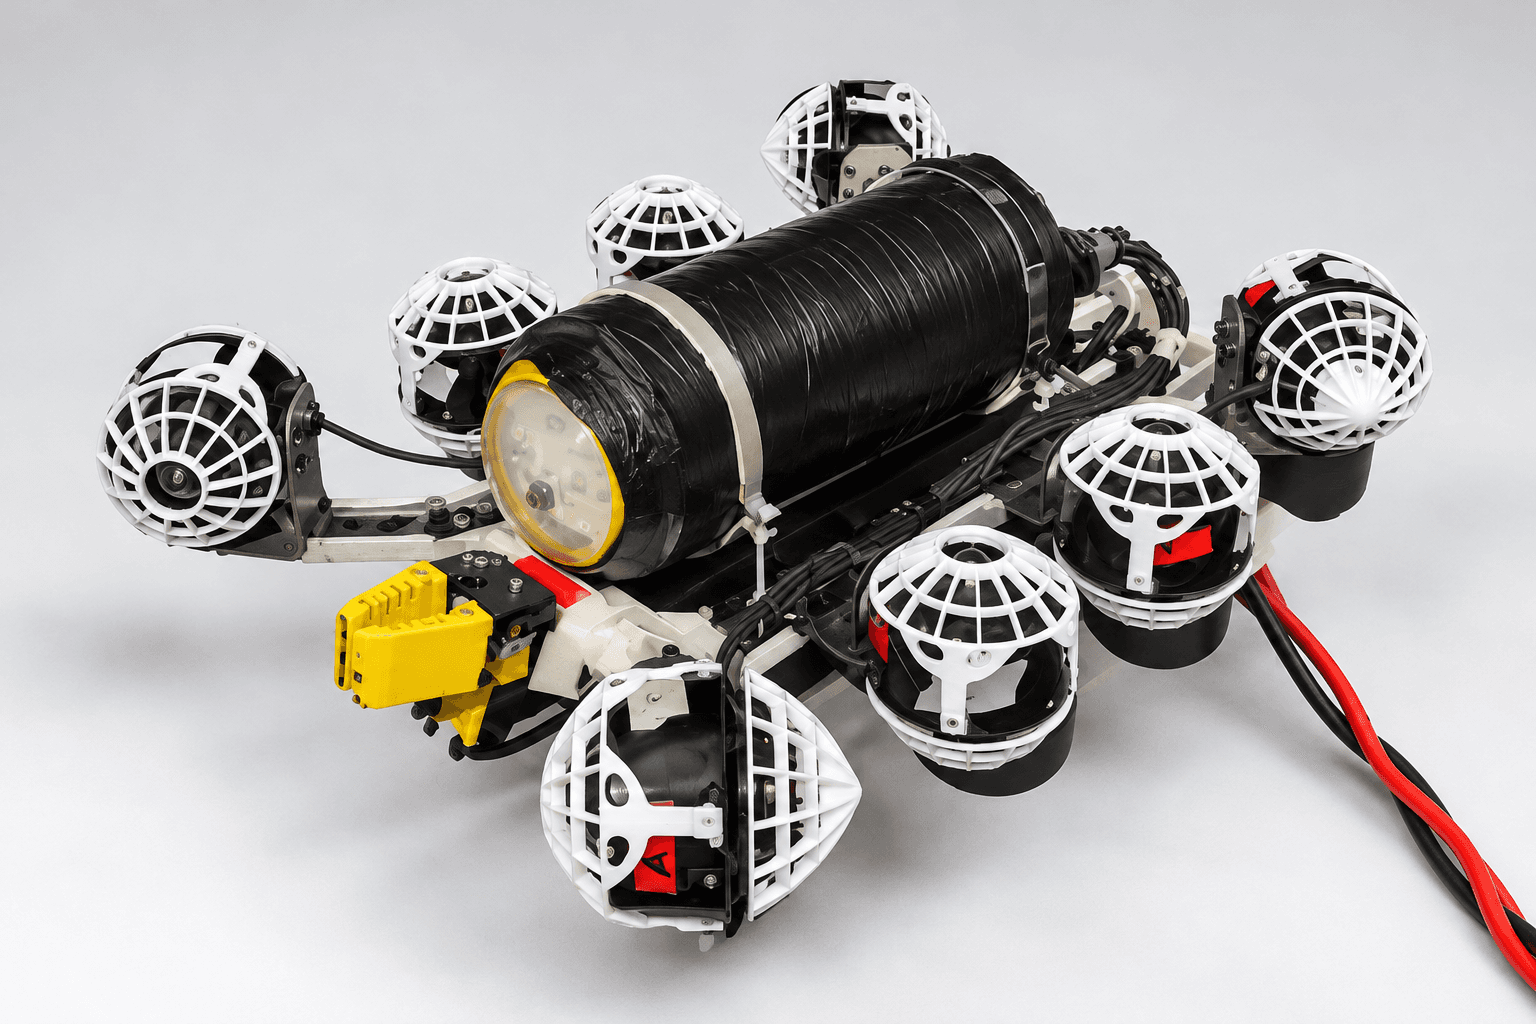
Octobot 2.0 is a compact underwater robot with eight vectored thrusters, a sealed cylindrical hull and 3D printed thruster shrouds. It is built for precise multi-axis manoeuvring and uses on-board vision for competition tasks.
The electronics live in one sealed cylindrical hull, and the frame holds that tube and eight thrusters around it.
Eight vectored thrusters give Octobot precise control on several axes at once, so it can hold position and line up on a task. The thruster shrouds are 3D printed in-house.
The first Octobot was a multi-thruster vehicle with a gripper for retrieving objects. Octobot 2.0 rebuilt the hull, frame and electronics around what the team learned from it, and added vision-guided autonomy with OpenCV.
Specifications
- Thrusters
- 8, vectored
- Hull
- Sealed cylindrical tube
- Shrouds
- 3D printed in-house
- Vision
- OpenCV
- Generations
- 1.0 and 2.0
Technology
- Vectored thrust
- Sealed tube hull
- OpenCV
- 3D printed shrouds
- Embedded control
Gallery